Flight Log · Lab notebook
Flight Log
Each sortie is a short lab entry: date, field, purpose, video, scored table, findings, and the next VIN fix. Trend chart tracks mean/max error across numbered flights. Scobee 19 Aug: Northern F0167 and Southern F0168 — GNSS anchors on those flights: none.
Nav error trend, m (mean · max)
GNSS anchors on these flights — none
Scobee Flying Field, 19 Aug 2026. The multicopter flew AUTO on GNSS. VIN ran in parallel. On the scored cruise there was no GNSS reset. Northern route (#0167): mean 1.74 m. Southern route (#0168): mean 1.4 m.
-
Southern route
Aug 19, 2026 · Scobee Flying Field · Flight #0168
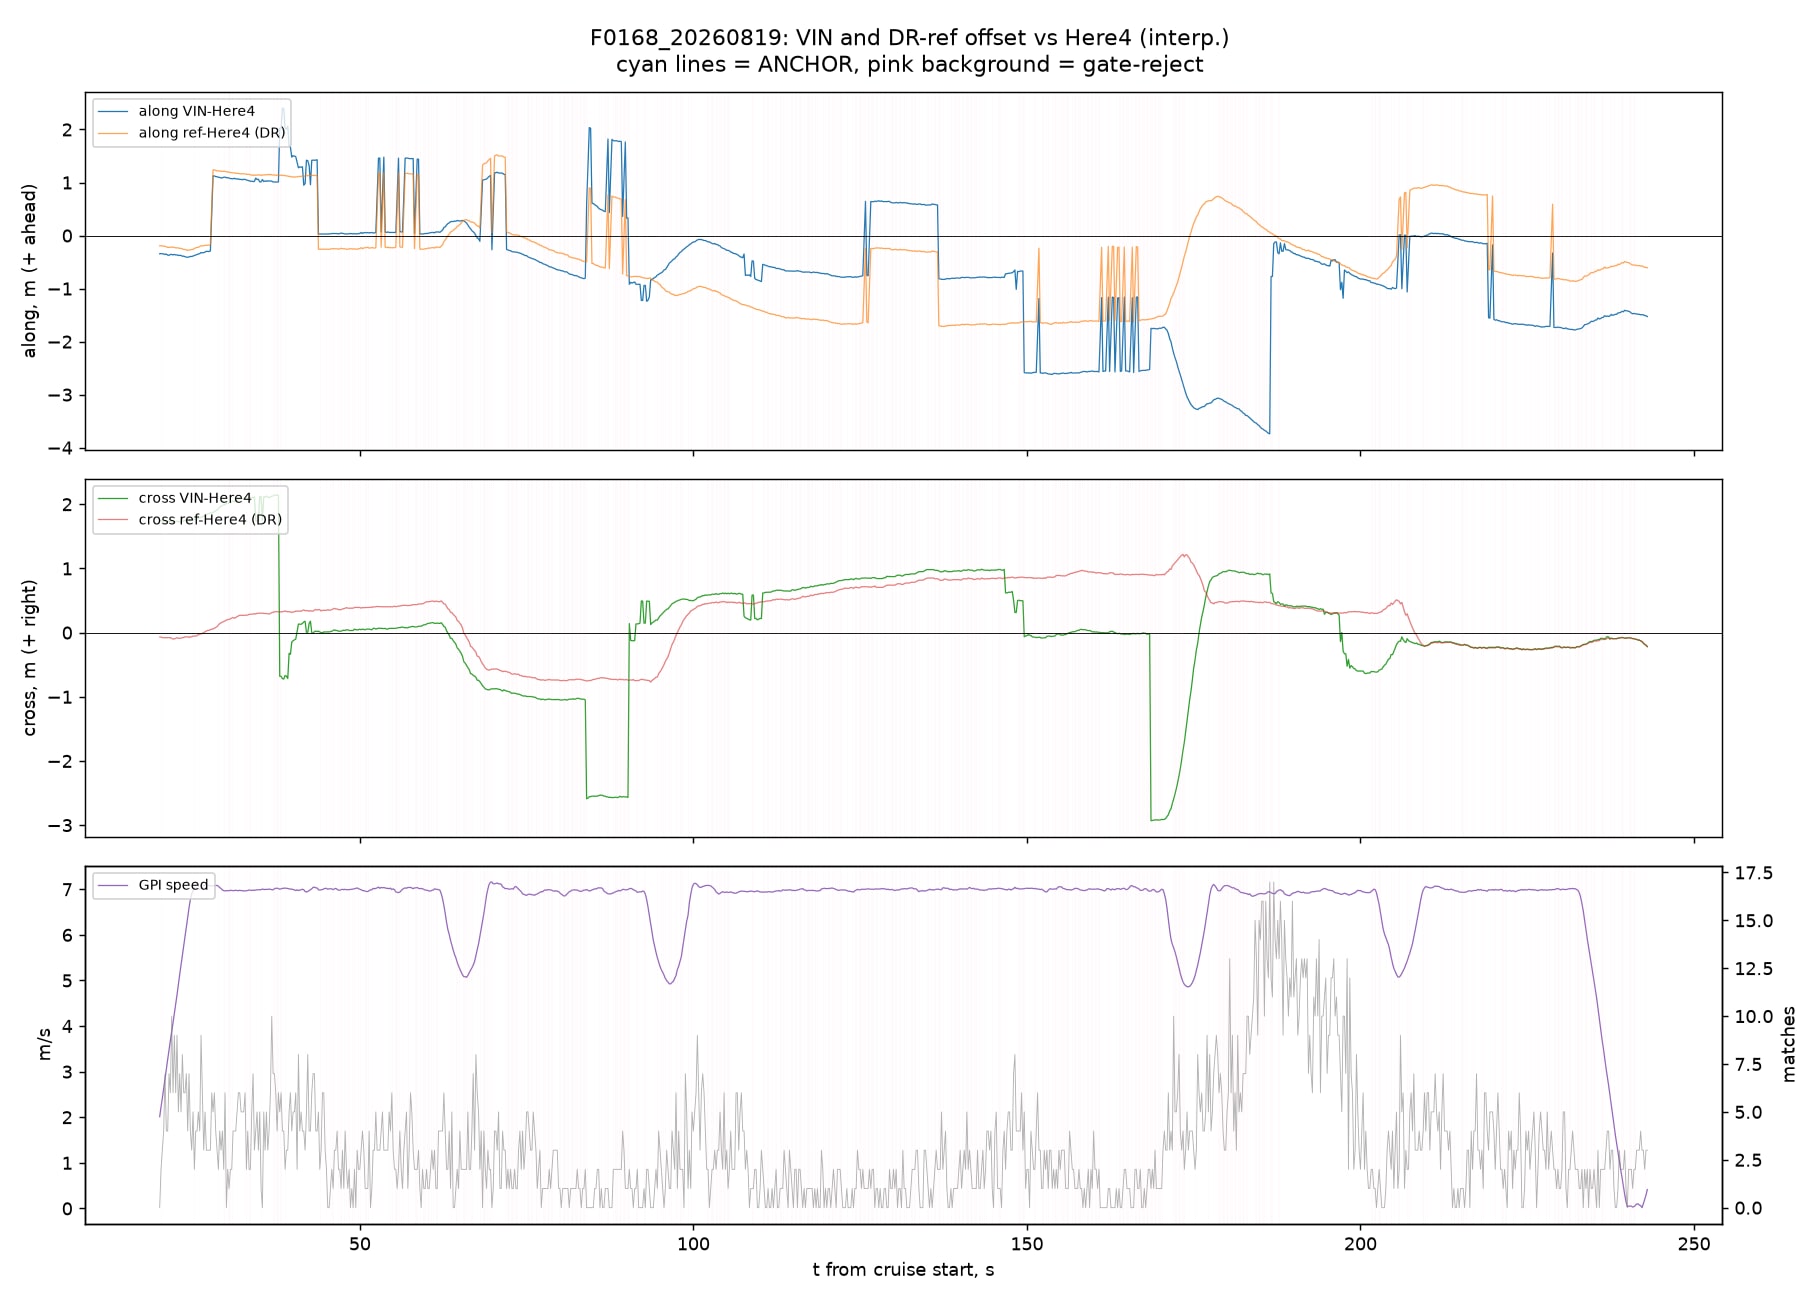
4.1 min · GPS reference available · VIN 5 Hz · Mean 1.4 m · Median 1.17 m · Max 3.85 m · 120 m AGL
GNSS anchors — none
Purpose
Southern AUTO loop at Scobee Flying Field. The multicopter flew AUTO on GNSS. VIN ran in parallel and was scored against Here4 on the cruise — no GNSS reset on the track.
Full-resolution file download — available with L1 access.
Flight report
Full scored table (.xlsx) — available with L1 access.
Findings
Scored cruise (~4.1 min at 120 m, 7 m/s): mean |VIN−Here4| 1.40 m, median 1.17 m, p90 2.62 m, max 3.85 m. VIN 5.0 Hz. GNSS anchors on the scored cruise: none. Path ~1.47 km, ~230 m south of the pad.
Next actions
Same Scobee loops with GNSS off VIN — the southern track already holds ~1.4 m mean without a route anchor.
-
Northern route
Aug 19, 2026 · Scobee Flying Field · Flight #0167
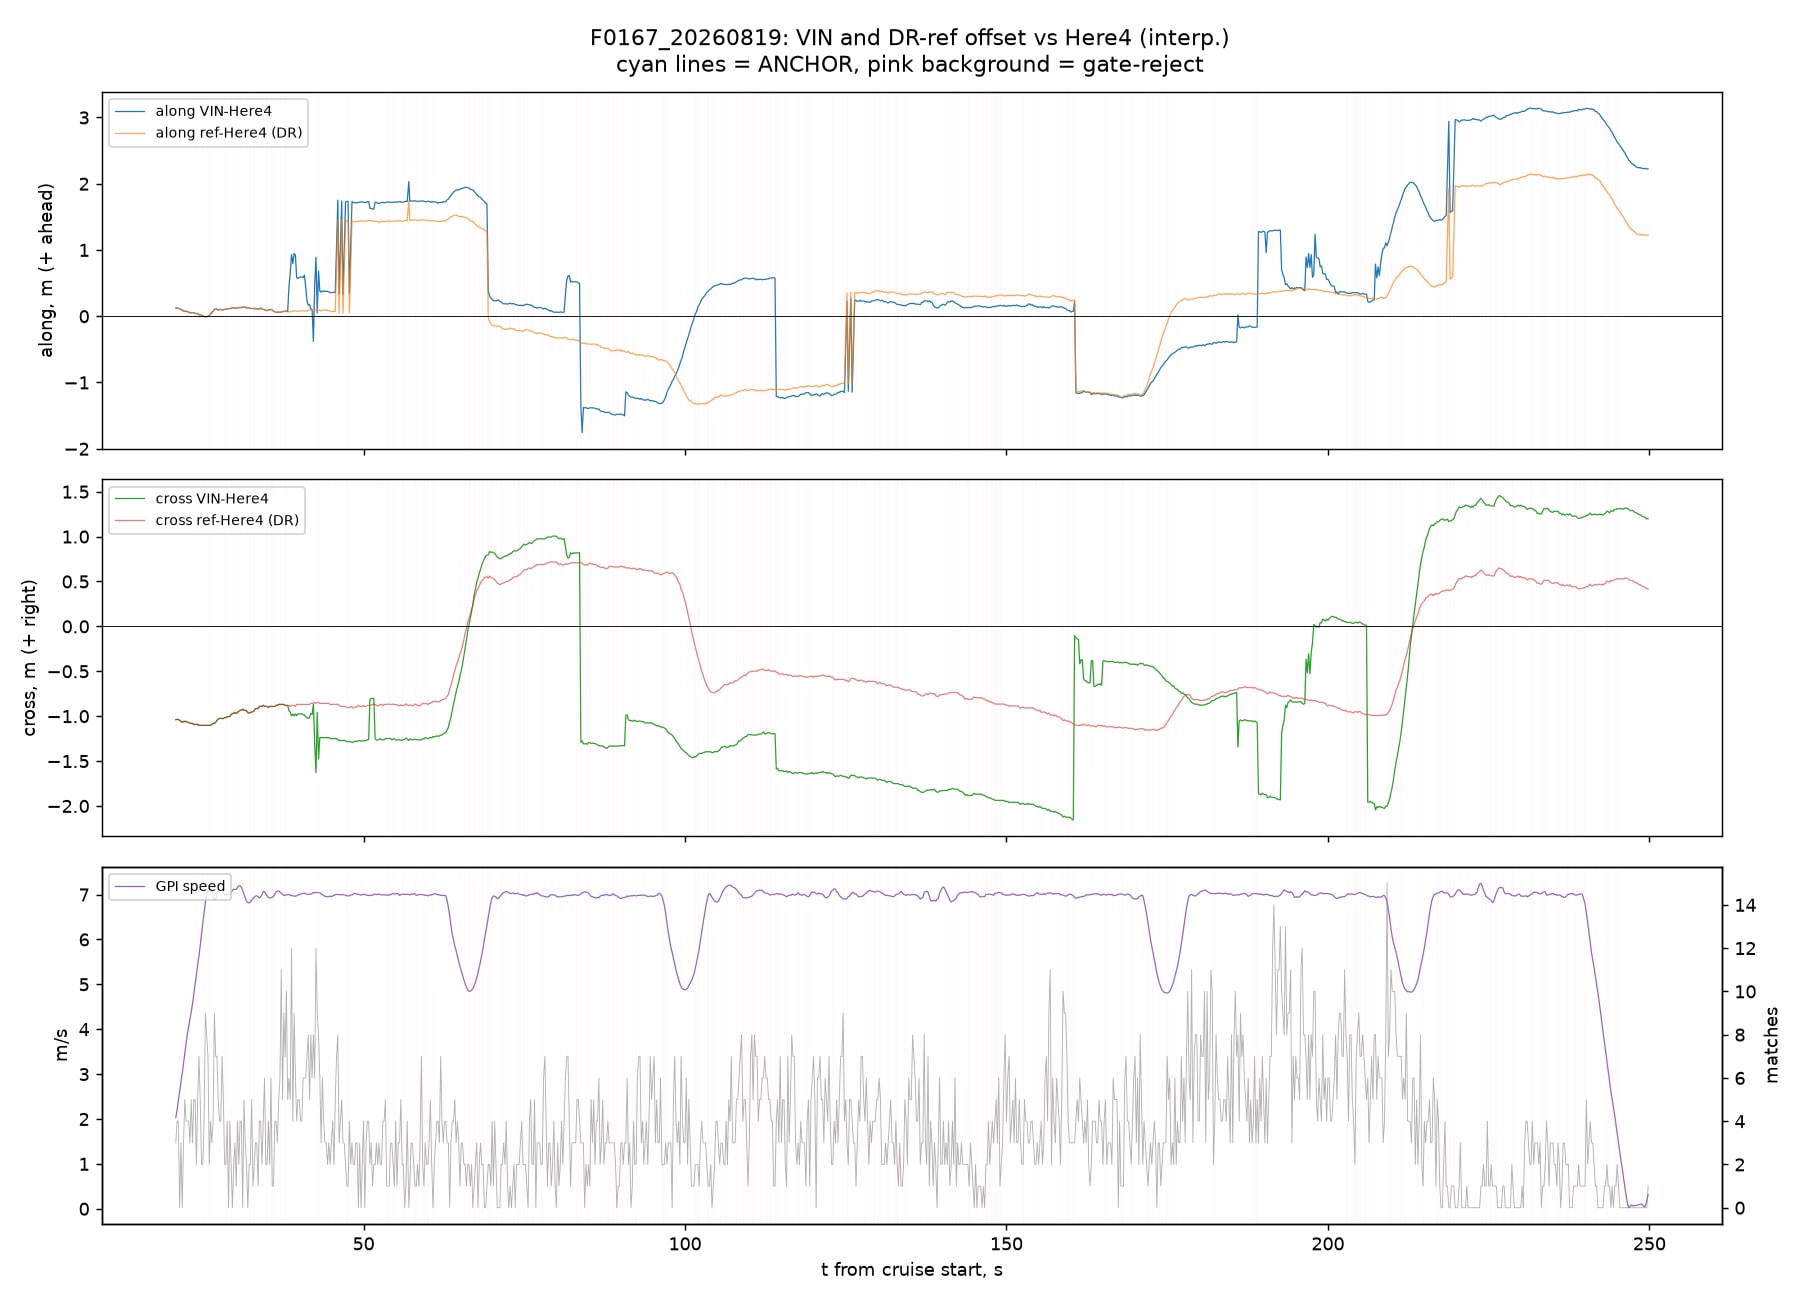
4.2 min · GPS reference available · VIN 5 Hz · Mean 1.74 m · Median 1.78 m · Max 3.41 m · 120 m AGL
GNSS anchors — none
Purpose
Northern AUTO loop at Scobee Flying Field. The multicopter flew AUTO on GNSS. VIN ran in parallel and was scored against Here4 on the cruise — no GNSS reset on the track.
Full-resolution file download — available with L1 access.
Flight report
Full scored table (.xlsx) — available with L1 access.
Findings
Scored cruise (~4.2 min at 120 m, 7 m/s): mean |VIN−Here4| 1.74 m, median 1.78 m, p90 3.22 m, max 3.41 m. VIN 5.0 Hz. GNSS anchors on the scored cruise: none (none on climb either). Path ~1.51 km, ~256 m north of the pad.
Next actions
Same Scobee loops with GNSS off VIN — the northern track already holds ~1.7 m mean without a route anchor.
-
Aug 14, 2026 · Ray Brickhouse Flying Field · Flight #0162
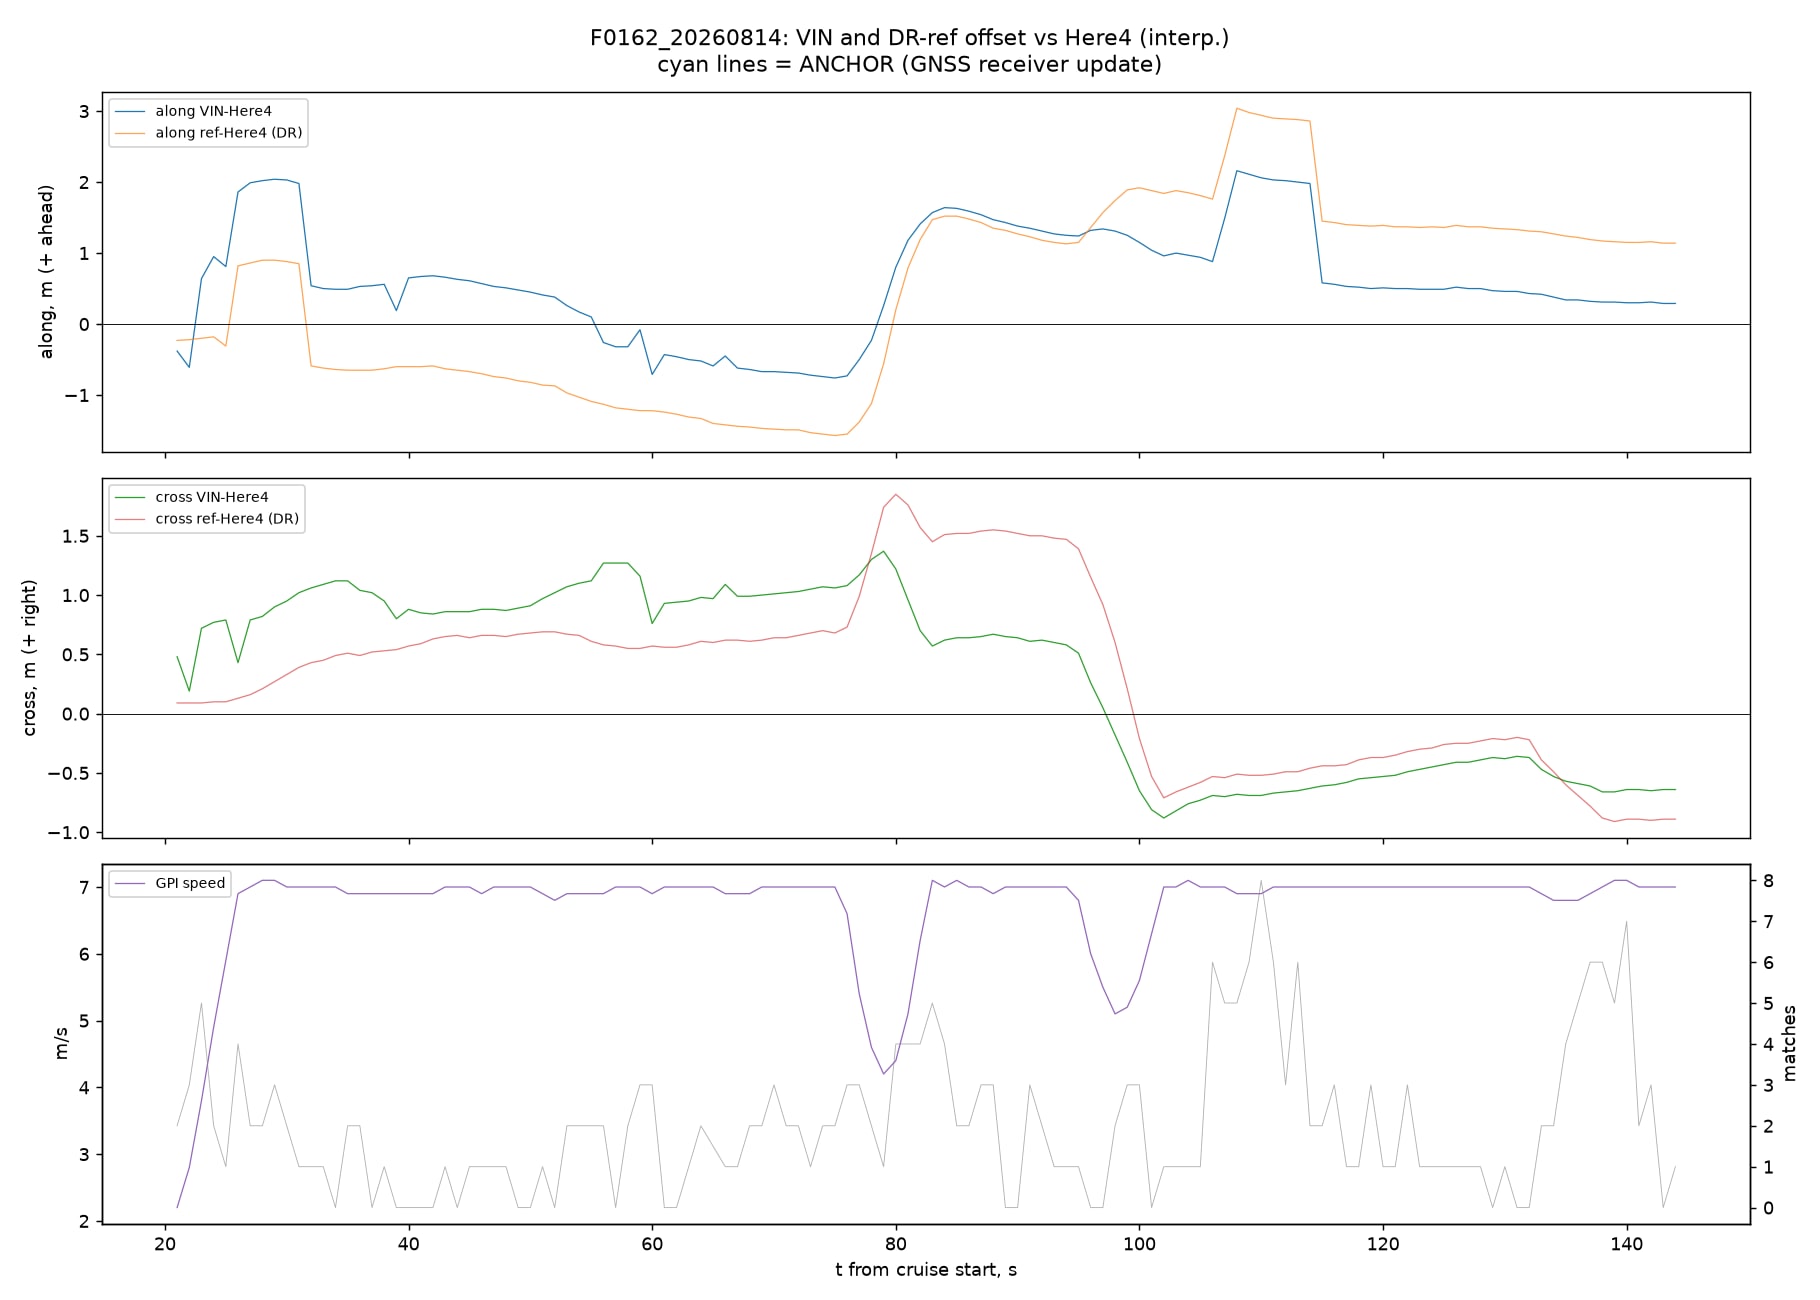
2.1 min · GPS reference available · VIN 4.5 Hz · Mean 1.2 m · Median 1.17 m · Max 2.26 m
Purpose
Field sortie at Ray Brickhouse Flying Field scoring VIN absolute position error against GPS ground truth with the GNSS receiver used only as a sparse 240 s anchor. Between updates the onboard pipeline computed global coordinates for the full track.
Full-resolution file download — available with L1 access.
Flight report
Full scored table (.xlsx) — available with L1 access.
Findings
Scored 1 Hz table over ~2.1 min: divergence median 1.17 m, mean 1.20 m, p90 1.86 m, max 2.26 m. GNSS-receiver cadence 240 s — no second in-cruise update in the scored window; the pipeline held globally referenced position for the remainder of the track. Vision lock held ~27% of frames. Not a GNSS-removed demonstration.
Next actions
Keep the 240 s sparse-receiver profile; next step is a receiver-removed sortie once lock duty-cycle is back in the earlier Ray / Scobee ledger range.
-
Aug 14, 2026 · Ray Brickhouse Flying Field · Flight #0159
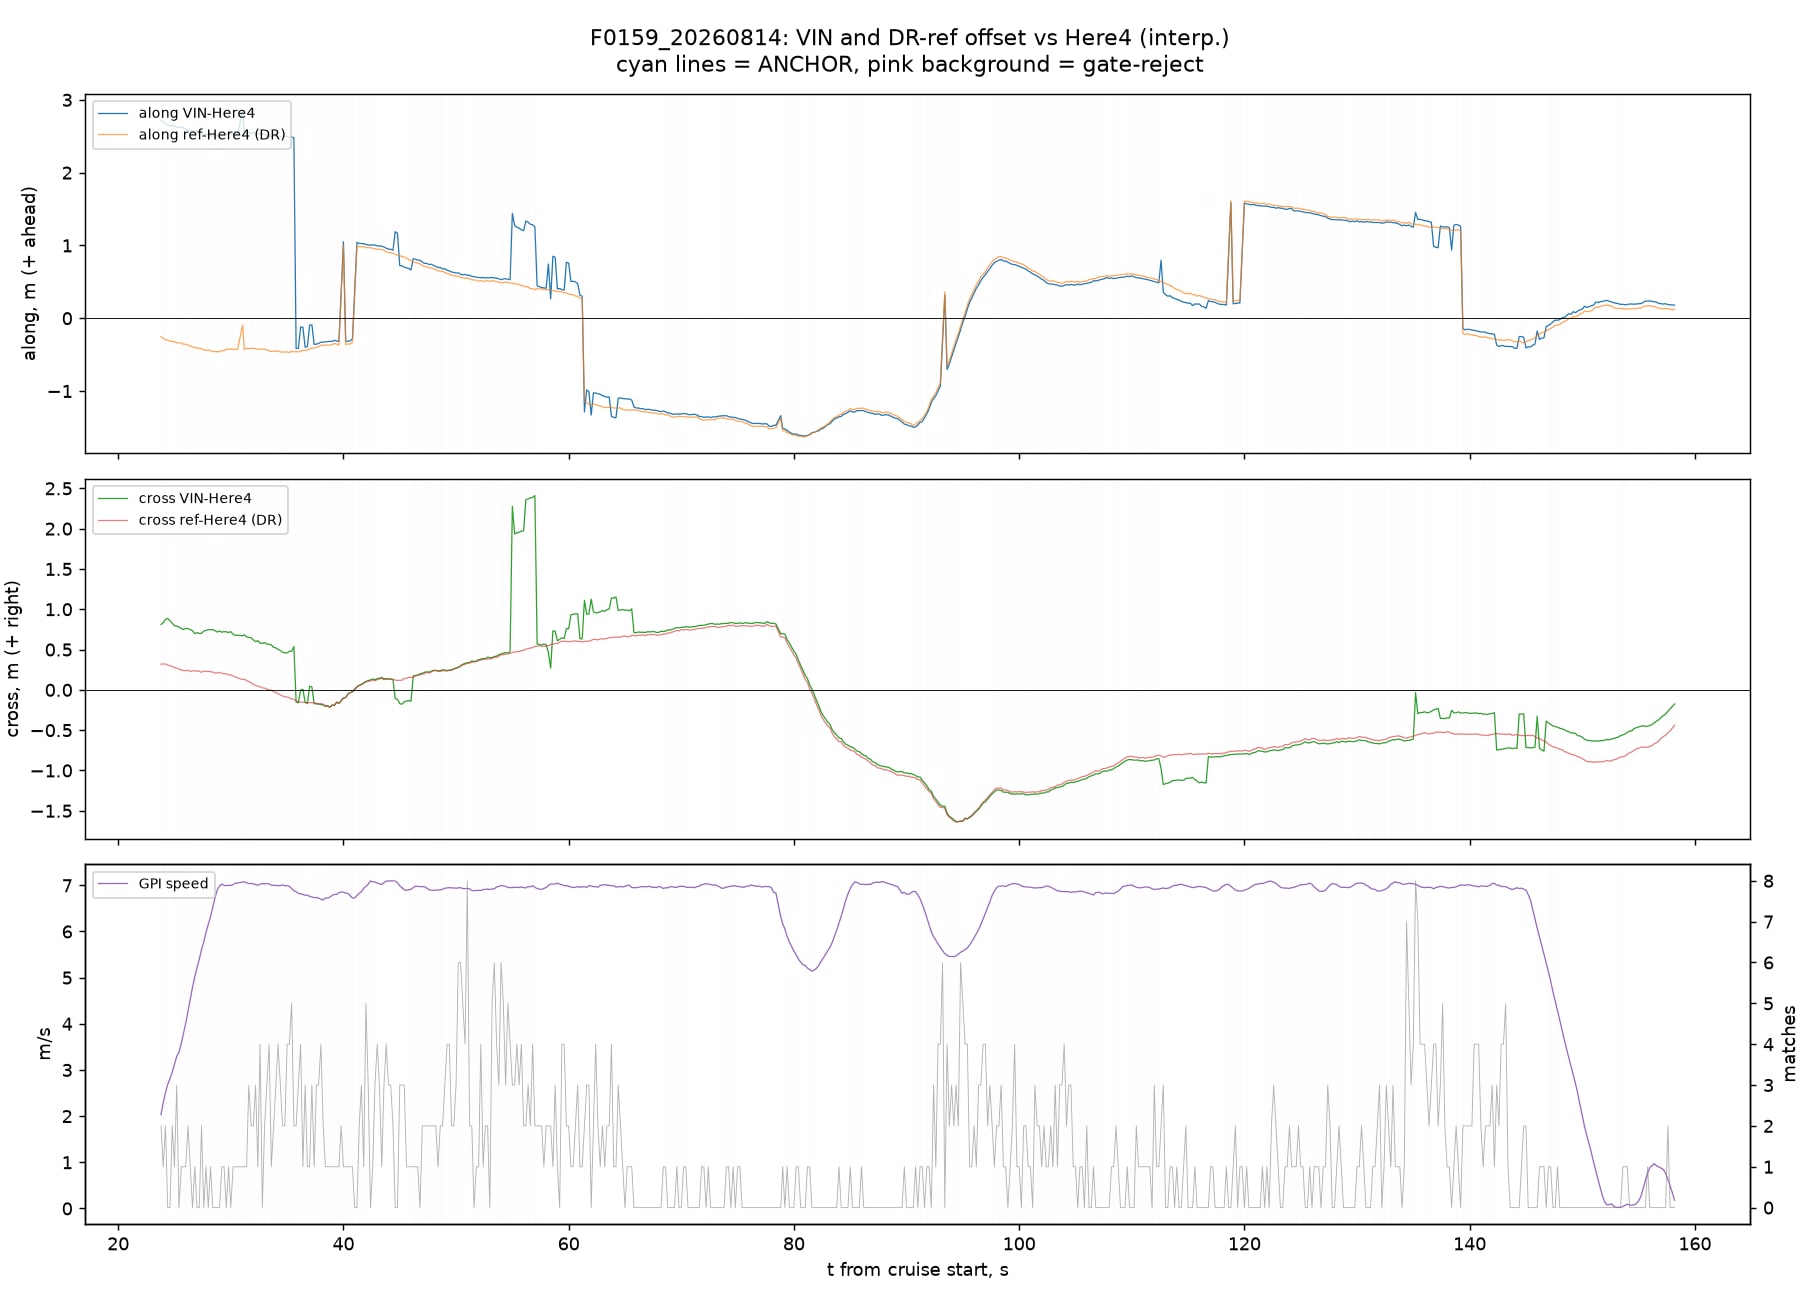
2.3 min · GPS reference available · VIN 5 Hz · Mean 1.32 m · Median 1.42 m · Max 2.84 m
Purpose
Field sortie at Ray Brickhouse Flying Field scoring VIN absolute position error against GPS ground truth with the GNSS receiver used only as a sparse 180 s anchor. Between updates the onboard pipeline computed global coordinates for the full track.
Full-resolution file download — available with L1 access.
Flight report
Full scored table (.xlsx) — available with L1 access.
Findings
Scored 1 Hz table over ~2.3 min: divergence median 1.42 m, mean 1.32 m, p90 2.42 m, max 2.84 m. One GNSS-receiver update at sortie start (180 s cadence; sortie shorter than a second interval). Remainder of the scored track is pipeline-computed global position. Vision lock held ~14% of frames. Not a GNSS-removed demonstration.
Next actions
Hold the 180 s receiver cadence and raise lock duty-cycle before stretching the interval further.
-
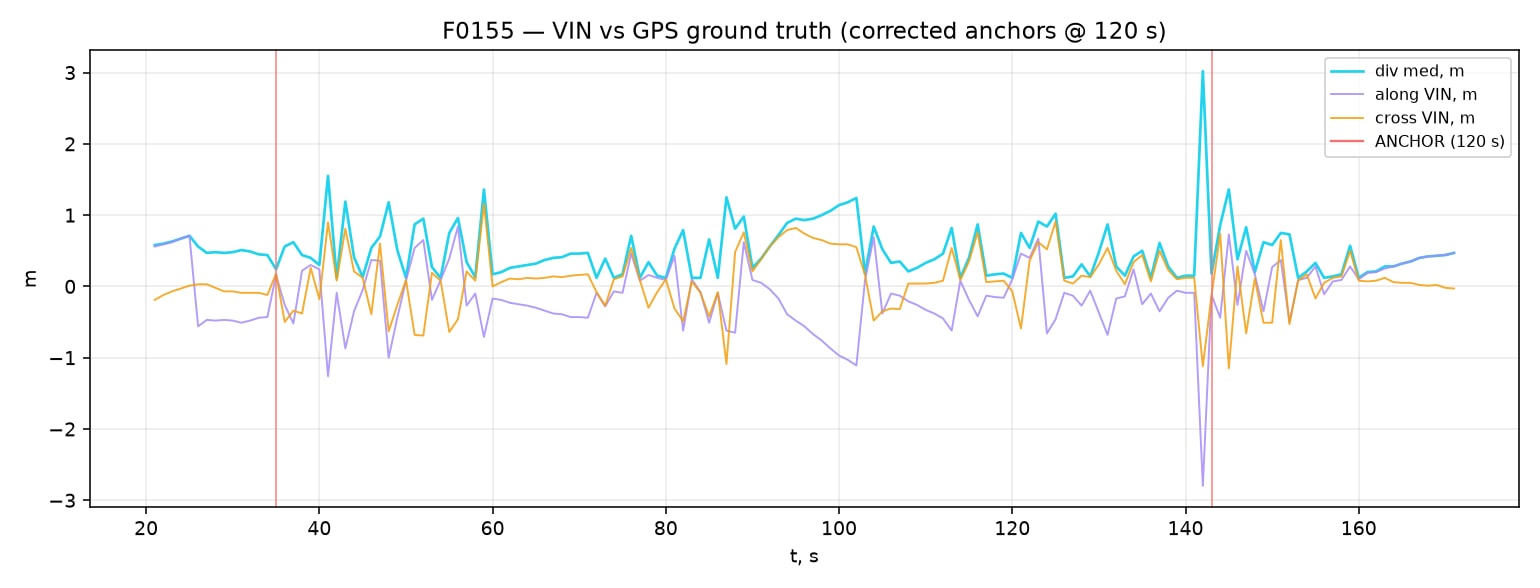
Aug 13, 2026 · Ray Brickhouse Flying Field · Flight #0155
2.5 min · GPS reference available · VIN 4.7 Hz · Mean 0.5 m · Median 0.42 m · Max 3.02 m
Purpose
Field sortie at Ray Brickhouse Flying Field scoring VIN absolute position error against GPS ground truth while exercising new onboard filter settings (filter details withheld).
Full-resolution file download — available with L1 access.
Flight report
Full scored table (.xlsx) — available with L1 access.
Findings
Scored 1 Hz table over ~2.5 min: divergence median 0.42 m, mean ~0.5 m, p90 0.95 m, max 3.02 m. GPS anchors held to the intended 120 s cadence (2 events). Sortie used to validate new filter behavior in live air — not a GNSS-removed demonstration.
Next actions
Carry the filter set into a longer GNSS-sparse / receiver-removed profile once lock duty-cycle is back in the Scobee / Ray Brickhouse ledger range.
-
Jul 24, 2026 · Scobee Flying Field · Flight #0121
5.4 min · GPS reference available · VIN 4.7 Hz · Mean 1.03 m · Median 1.2 m · Max 3.19 m
Purpose
Field validation of VIN absolute position error against GPS ground truth at Scobee Flying Field (AMA community) — quantify locked-mode accuracy and unlock/reacquire behavior over a full sortie.
Full-resolution file download — available with L1 access.
Flight report

Full scored table (.xlsx) — available with L1 access.
Findings
Locked-mode error: median 1.2 m, mean 1.03 m, max 3.19 m; 99.8% of locked frames ≤ 3 m. Vision lock held ~56% of frames (~861/1530); the dominant unlock path was reacquire_consistency (587 frames), with a smaller share from few_matches. Achieved VIN rate ~4.7 Hz over ~5.4 min. Four GPS-anchor events at ~105 s mean interval.
Next actions
Tighten the reacquire_consistency gate and reduce unlock churn so lock duty-cycle rises without inflating locked-mode error.
-
Jul 24, 2026 · Scobee Flying Field · Flight #0120
5.4 min · GPS reference available · VIN 4.7 Hz · Mean 1.01 m · Median 0.9 m · Max 14.91 m
Purpose
Same-day Scobee Flying Field baseline before F0121 — score VIN locked-mode error and lock duty-cycle against GPS ground truth.
Full-resolution file download — available with L1 access.
Flight report

Full scored table (.xlsx) — available with L1 access.
Findings
Strong lock hold: vision_ok ~93.8% of frames (1429/1524). Locked-mode median 0.9 m, mean 1.01 m, p90 1.49 m; 98.7% ≤ 3 m. Outlier max 14.91 m remains — a short spike, not the typical locked state. VIN ~4.7 Hz over ~5.4 min; three GPS-anchor events. Unlock reasons were mostly few_matches / orb_logged_few_matches (no reacquire_consistency storm as in F0121).
Next actions
Add / harden outlier rejection on locked-mode innovation so rare spikes (max ~15 m) are gated without hurting the sub-meter median.
-
Jul 23, 2026 · Ray Brickhouse Flying Field · Flight #0117
4.2 min · GPS reference available · VIN 4.6 Hz · Mean 0.68 m · Median 0.55 m · Max 3.29 m
Purpose
Field validation at Ray Brickhouse Flying Field — score VIN locked-mode absolute error against GPS ground truth on a different AMA community site than Scobee Flying Field.
Full-resolution file download — available with L1 access.
Flight report

Full scored table (.xlsx) — available with L1 access.
Findings
Best locked accuracy so far in this ledger: median 0.55 m, mean 0.68 m, max 3.29 m; 99.8% of locked frames ≤ 3 m and 76.8% ≤ 1 m. Lock duty-cycle only ~45% (522/1160); dominant unlock path reacquire_consistency (425 frames), then few_matches / innovation_gate. VIN ~4.6 Hz over ~4.2 min; five GPS-anchor events at ~60 s mean interval.
Next actions
Same theme as Scobee Flying Field F0121: raise lock duty-cycle by tightening reacquire_consistency without giving up the sub-meter locked median.
-
Jul 21, 2026 · Ray Brickhouse Flying Field · Flight #0109
4.2 min · GPS reference available · VIN 4.6 Hz · Mean 0.7 m · Median 0.41 m · Max 3.73 m
Purpose
Snake-pattern sortie at Ray Brickhouse Flying Field (snake3) — score VIN locked-mode absolute error against GPS ground truth under dense turning / lane changes.
Full-resolution file download — available with L1 access.
Flight report

Full scored table (.xlsx) — available with L1 access.
Findings
Strong combined result: lock duty-cycle ~96% (1105/1151) with locked-mode median 0.41 m, mean 0.7 m, max 3.73 m; 99% of locked frames ≤ 3 m and 71.4% ≤ 1 m. Unlock noise was low (few_matches 36, reacquire_consistency only 7). VIN ~4.6 Hz over ~4.2 min. GPS-anchor cadence was high (47 fires, ~5.4 s mean interval) — note when comparing to later Ray Brickhouse / Scobee Flying Field runs with sparser anchors.
Next actions
Use this snake3 profile as a high-lock baseline; verify the same median holds when GPS-anchor interval is lengthened toward the ~60–105 s regime used on later flights.